About Me
I'm Haoming, a master's student in artificial intelligence at the University of Chinese Academy of Sciences (UCAS). My research focuses on robotics, particularly on building robotic systems that can navigate and manipulate objects in entirely unfamiliar environments. I believe Physical AI is the next step toward artificial general intelligence (AGI). My recent interests span different world model paradigms, agentic robotics, and related topics.
I'm currently interning at AGIBOT and have previously interned at Flexiv and Rightly Robotics.
I'm seeking industry positions and PhD opportunities starting in 2027. If you're interested in collaborating, please feel free to get in touch.
Research Interests
- Robotics: vision-language-action models, embodied agents and memory
- Multimodal Large Language Models
Publications
-
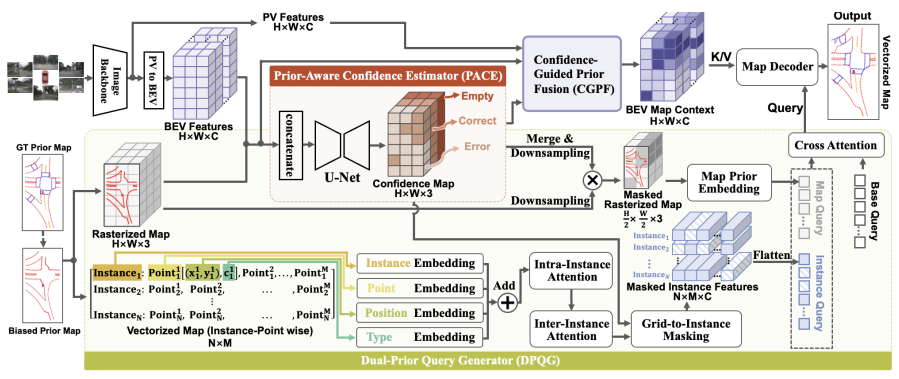 ECCV 2026
PriorMaskMap: Robust Online Vectorized Map Construction with Biased Priors
European Conference on Computer Vision (ECCV), 2026.
Confidence-guided use of imperfect prior maps for robust online vectorized mapping.
-
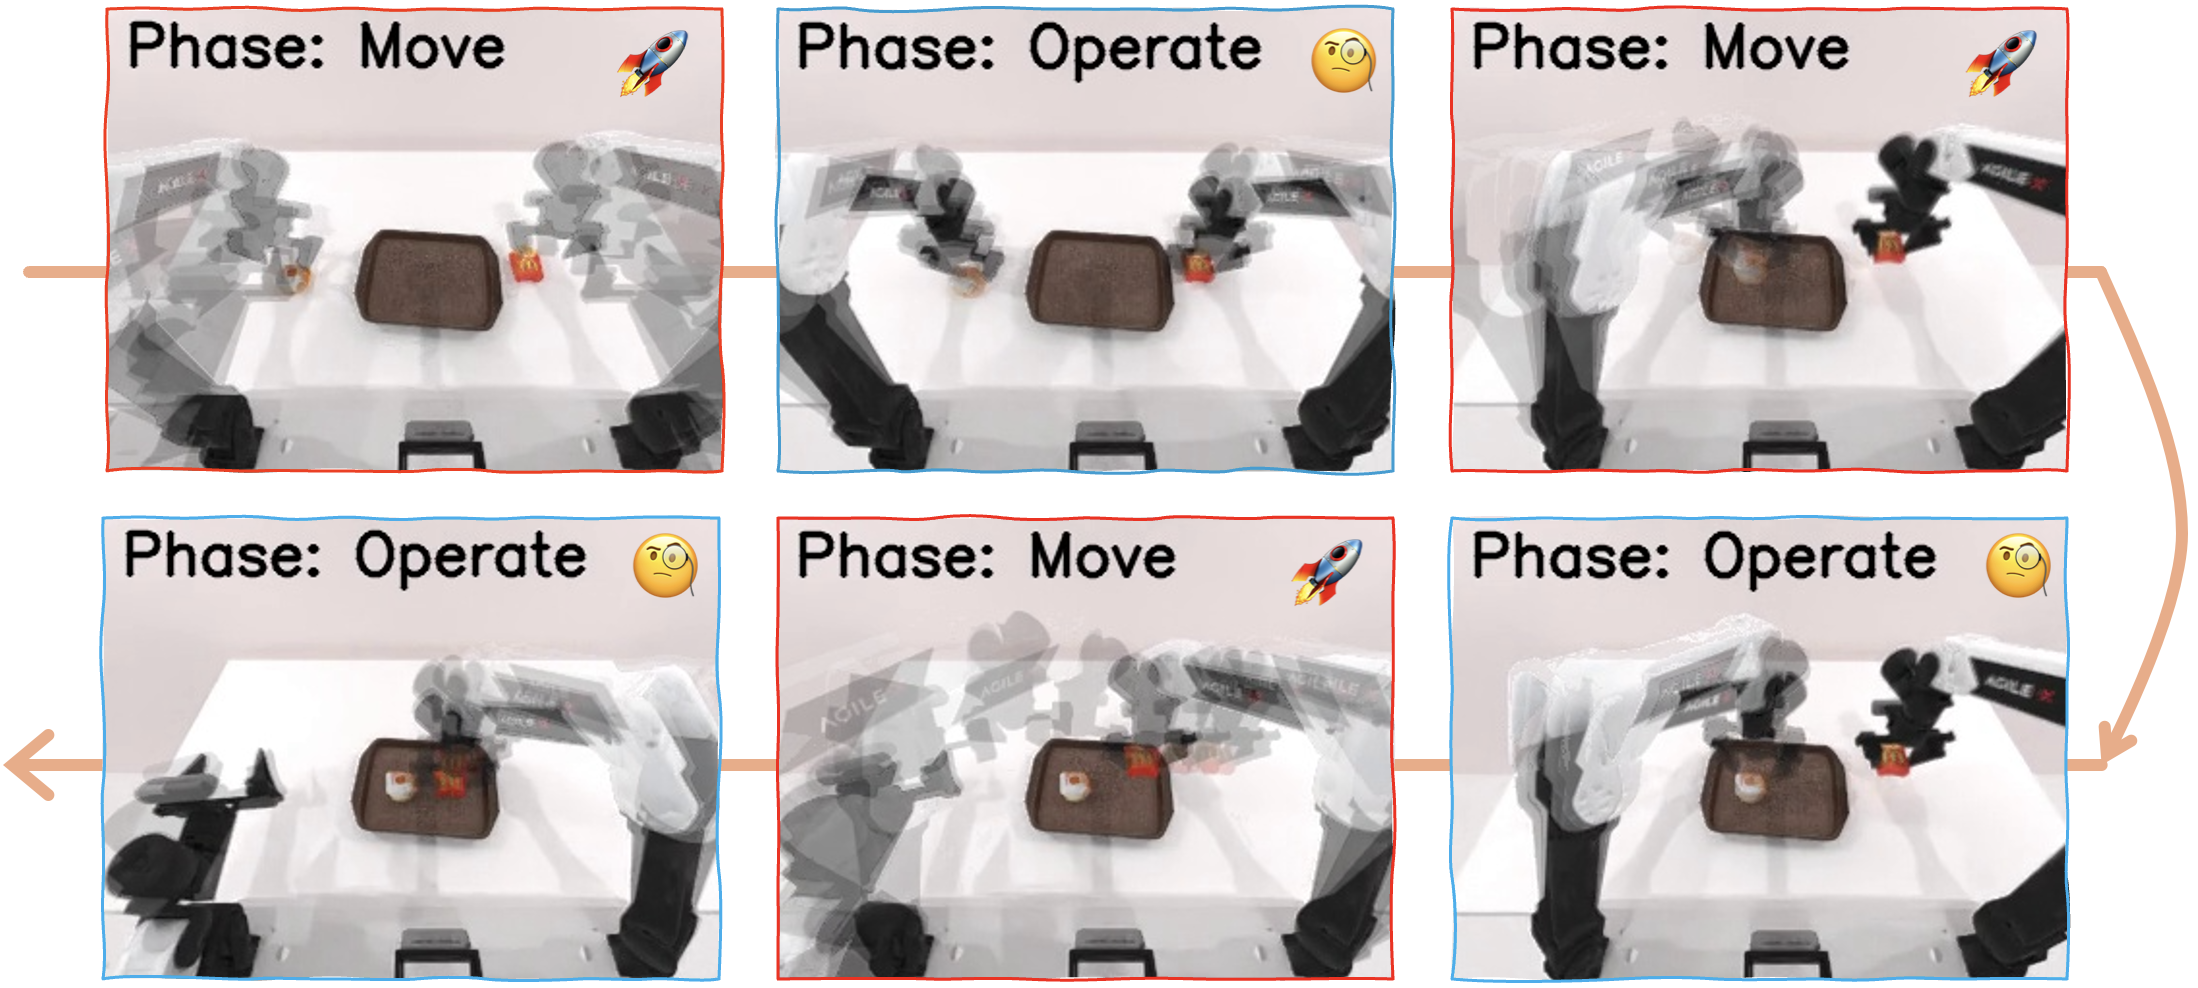 ICML 2026
Move-Then-Operate: Behavioral Phasing for Human-Like Robotic Manipulation
International Conference on Machine Learning (ICML), 2026.
A dual-expert VLA policy separating coarse movement from precise interaction.
-
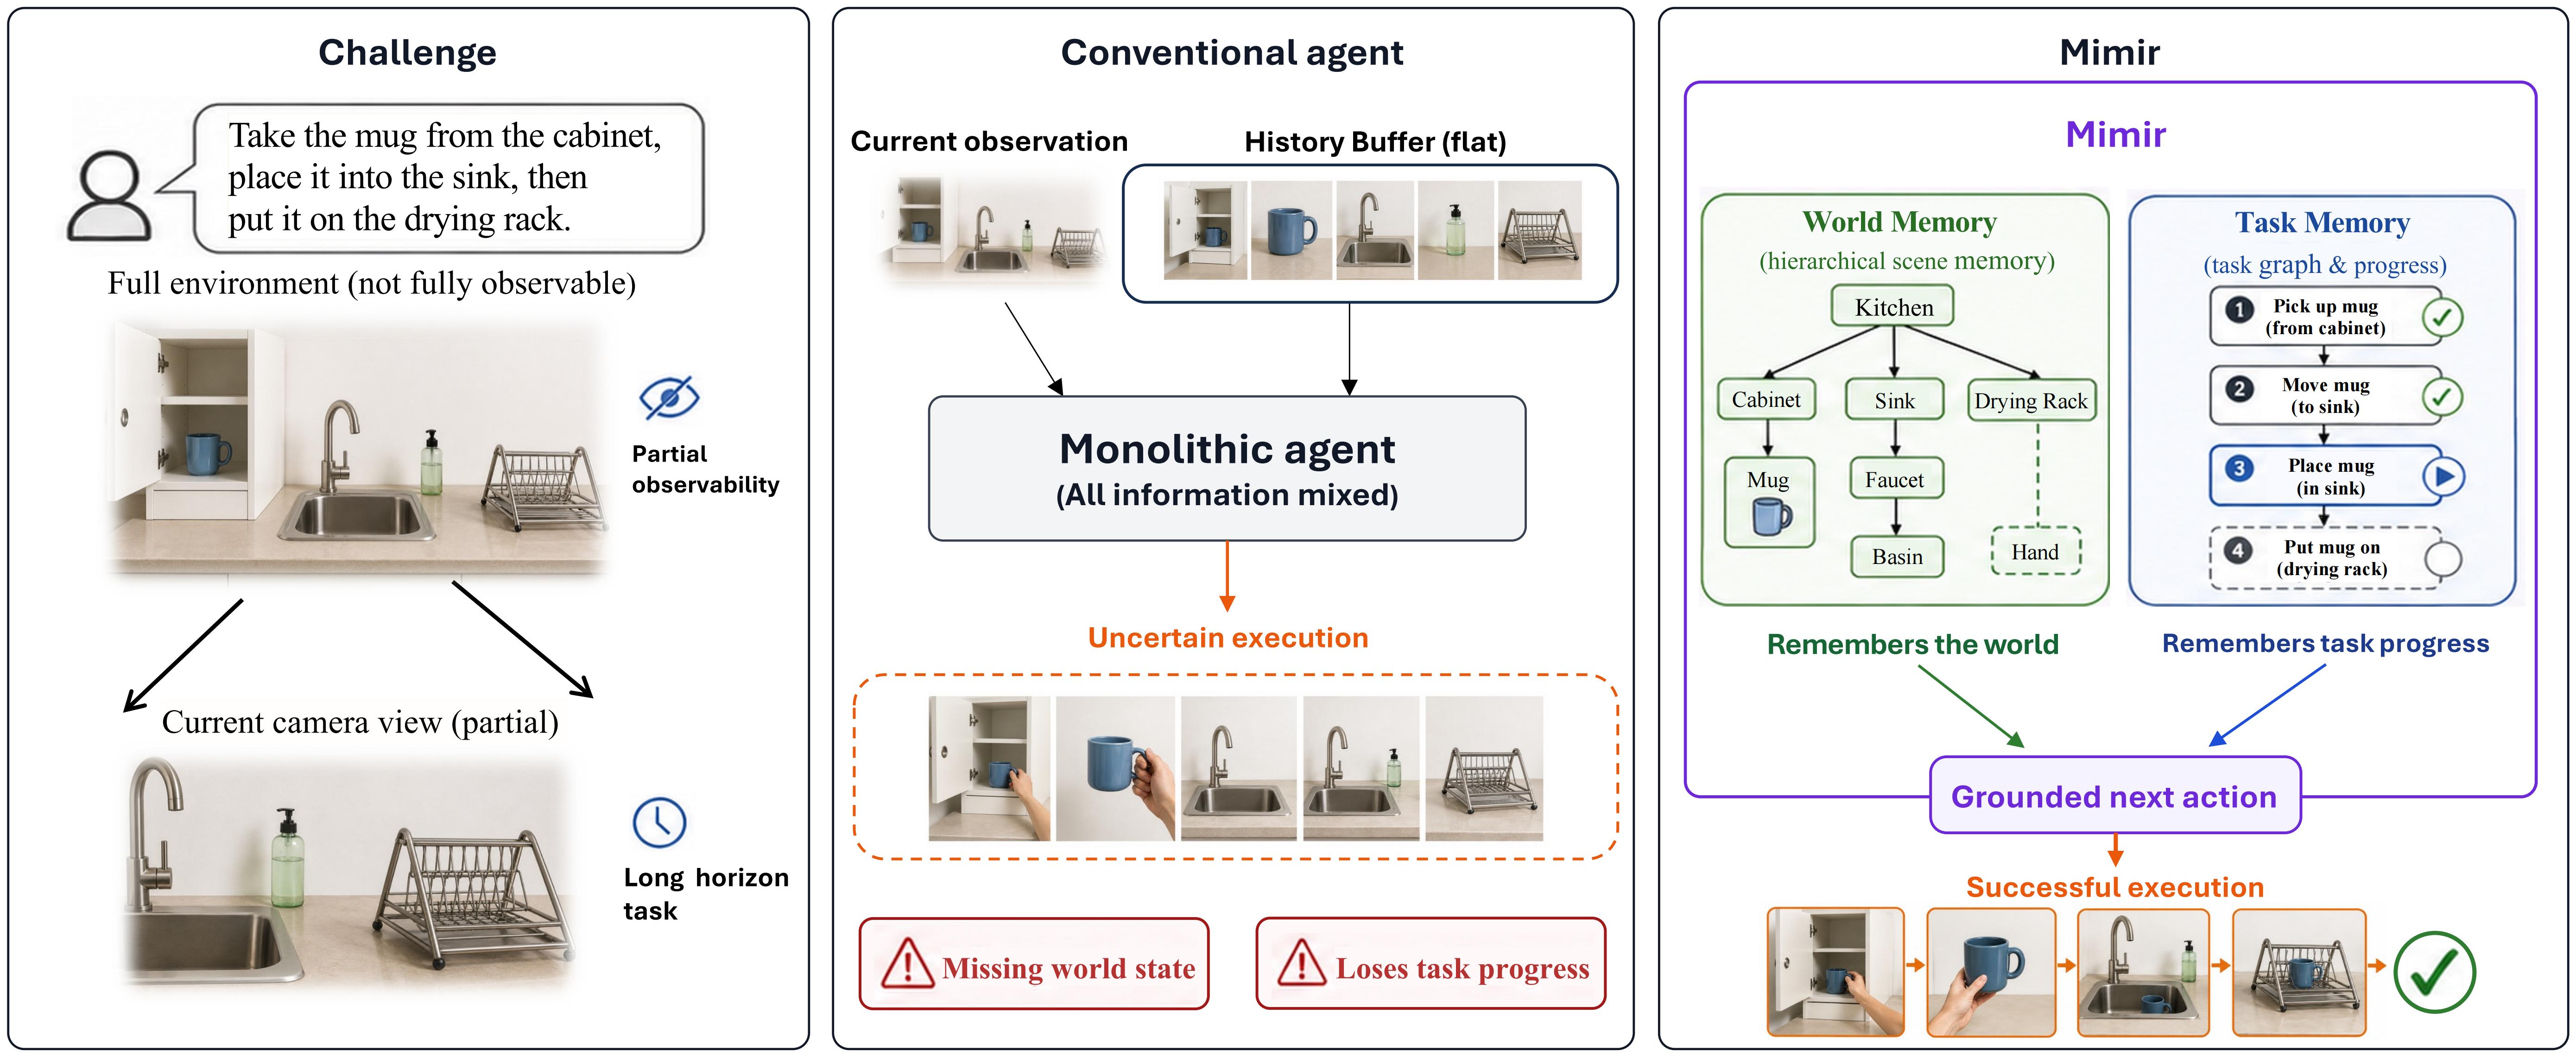 arXiv 2026
Mimir: A Neuro-Symbolic Memory System with Dynamic Grounding for Embodied Agents in Interactive Environments
arXiv preprint, 2026.
Connecting world state and task progress through memory and dynamic grounding.
-
 IV 2025
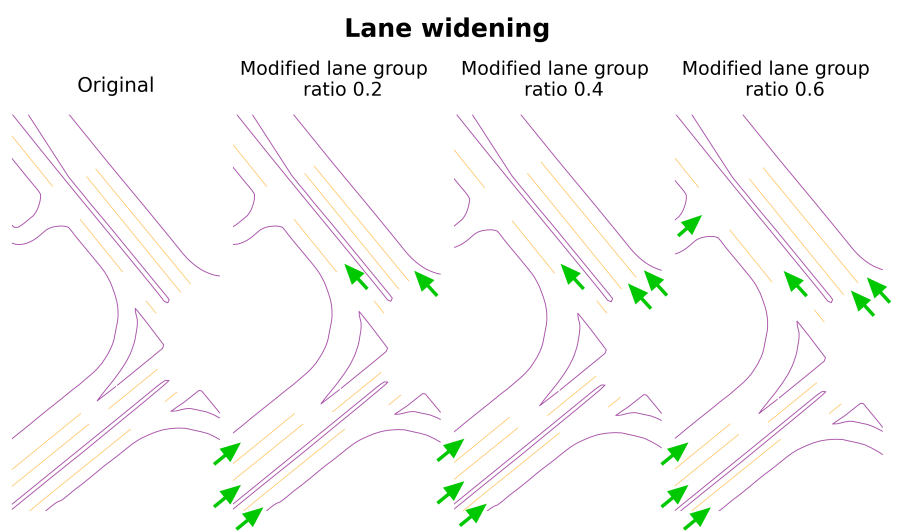
Generating Synthetic Deviation Maps for Prior-Enhanced Vectorized HD Map Construction
IEEE Intelligent Vehicles Symposium (IV), 2025, pp. 419–426.
Controllable geometric, topological, and semantic deviations for prior-map evaluation.